Survey-grade. Real-time. GPS-free.
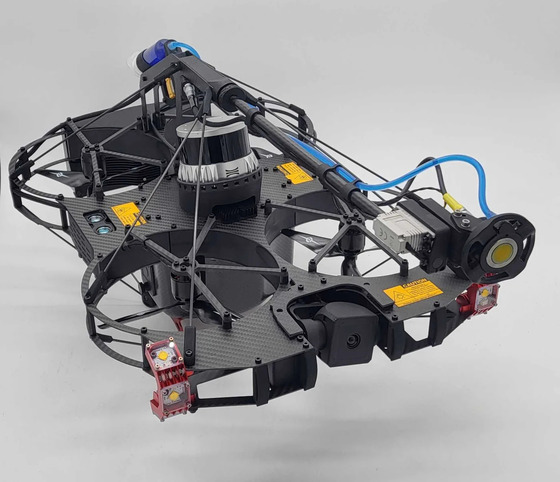
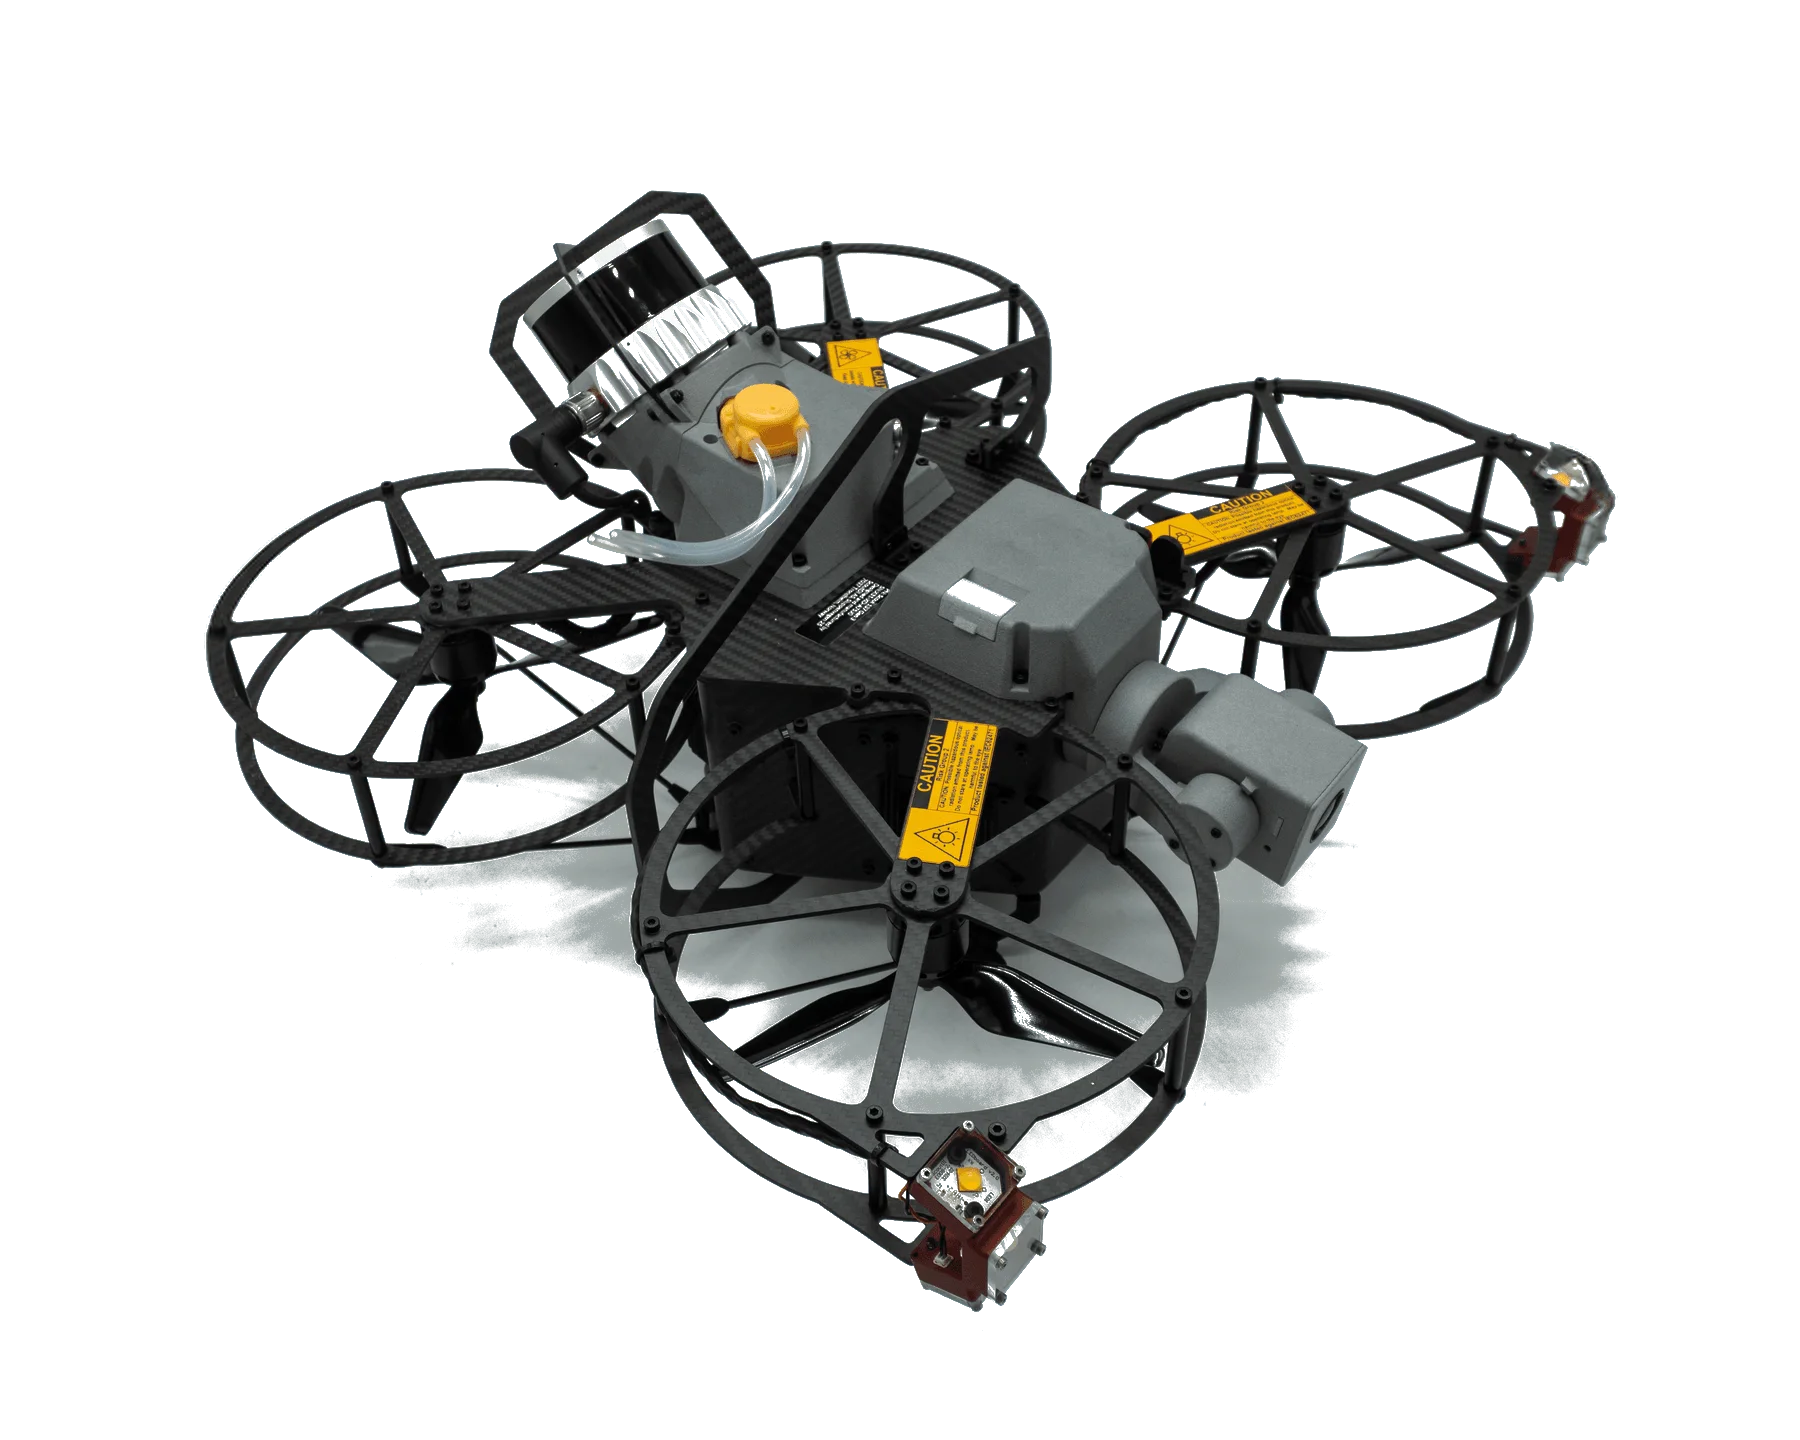
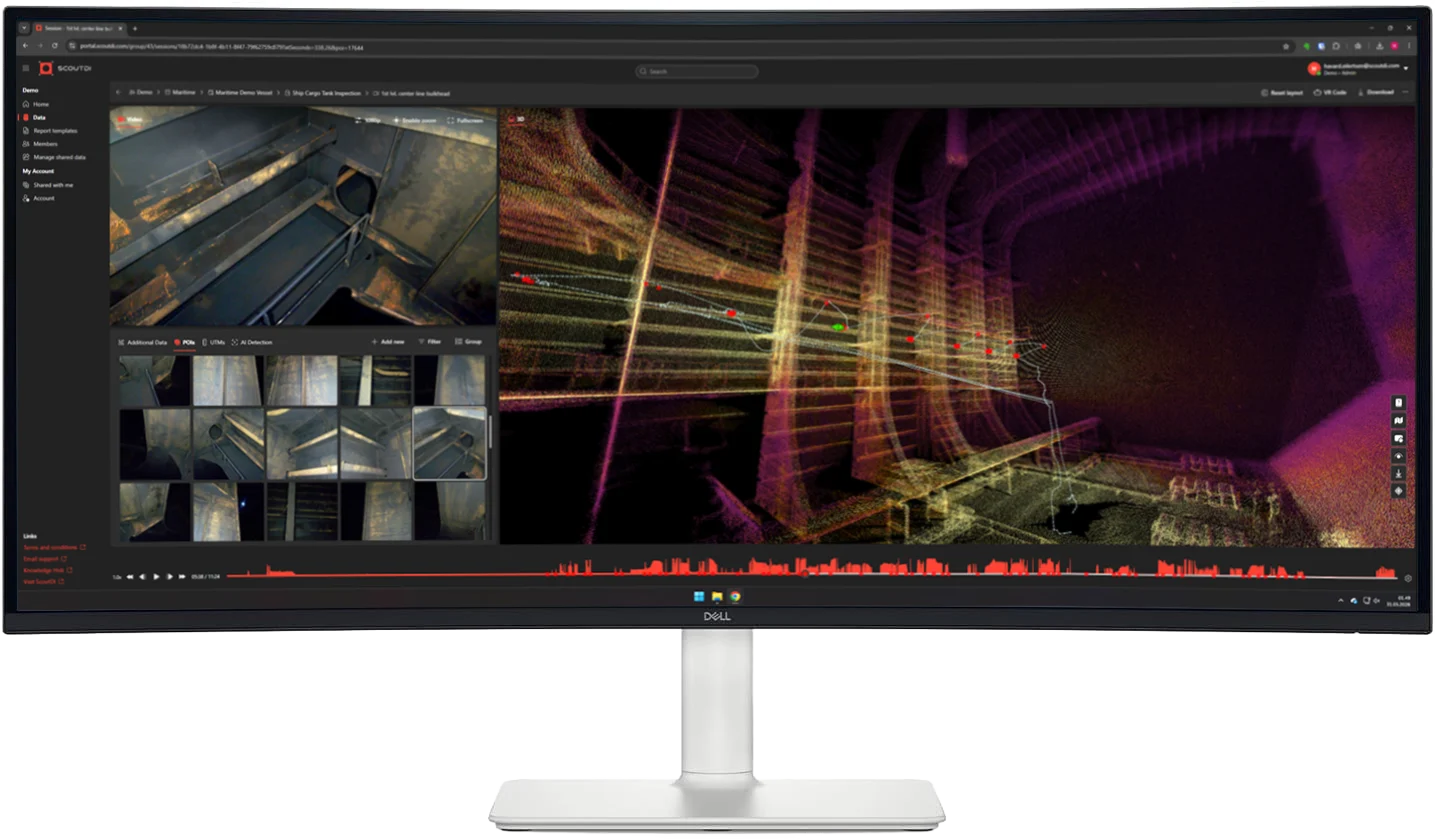
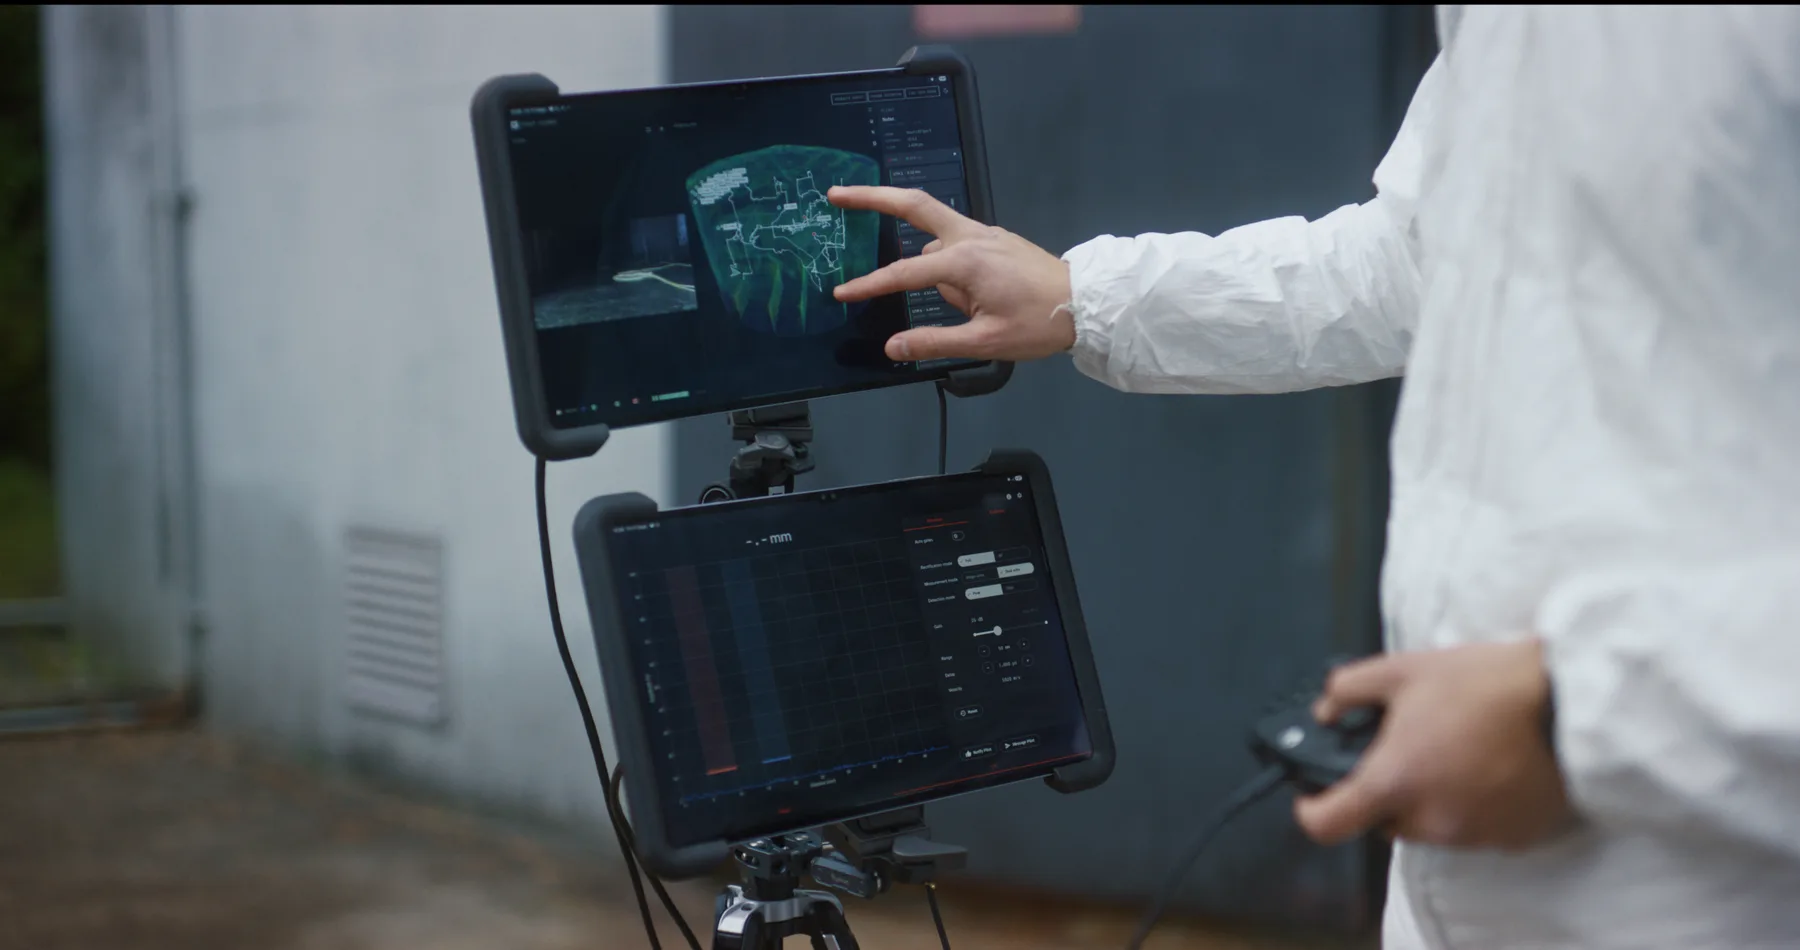
The 3D LiDAR payload turns one Scout 137 flight into a navigable point cloud of the entire asset interior. Same sensor handles SLAM localization in real time. The result lands in Scout Portal as a 3D model that every other measurement attaches to.
Survey-grade point cloud
The LiDAR captures up to 5.24 million measurements per second at survey-grade precision (down to a 1 mm range resolution). One pass through a cargo tank, distillation column or penstock returns the complete interior surface as a dense point cloud — tuned for close geometry, with up to 75 m range (35 m on dark, 10%-reflectivity surfaces) for the rare large space.
What used to take a static terrestrial survey rig and two days of setup happens in a 15-minute flight. And survey-grade comes standard: the LiDAR is built into every Scout 137 Gen 3 and runs on every flight — not a payload you mount, a rig you rent, or a premium add-on.
The sensor that maps is the sensor that flies
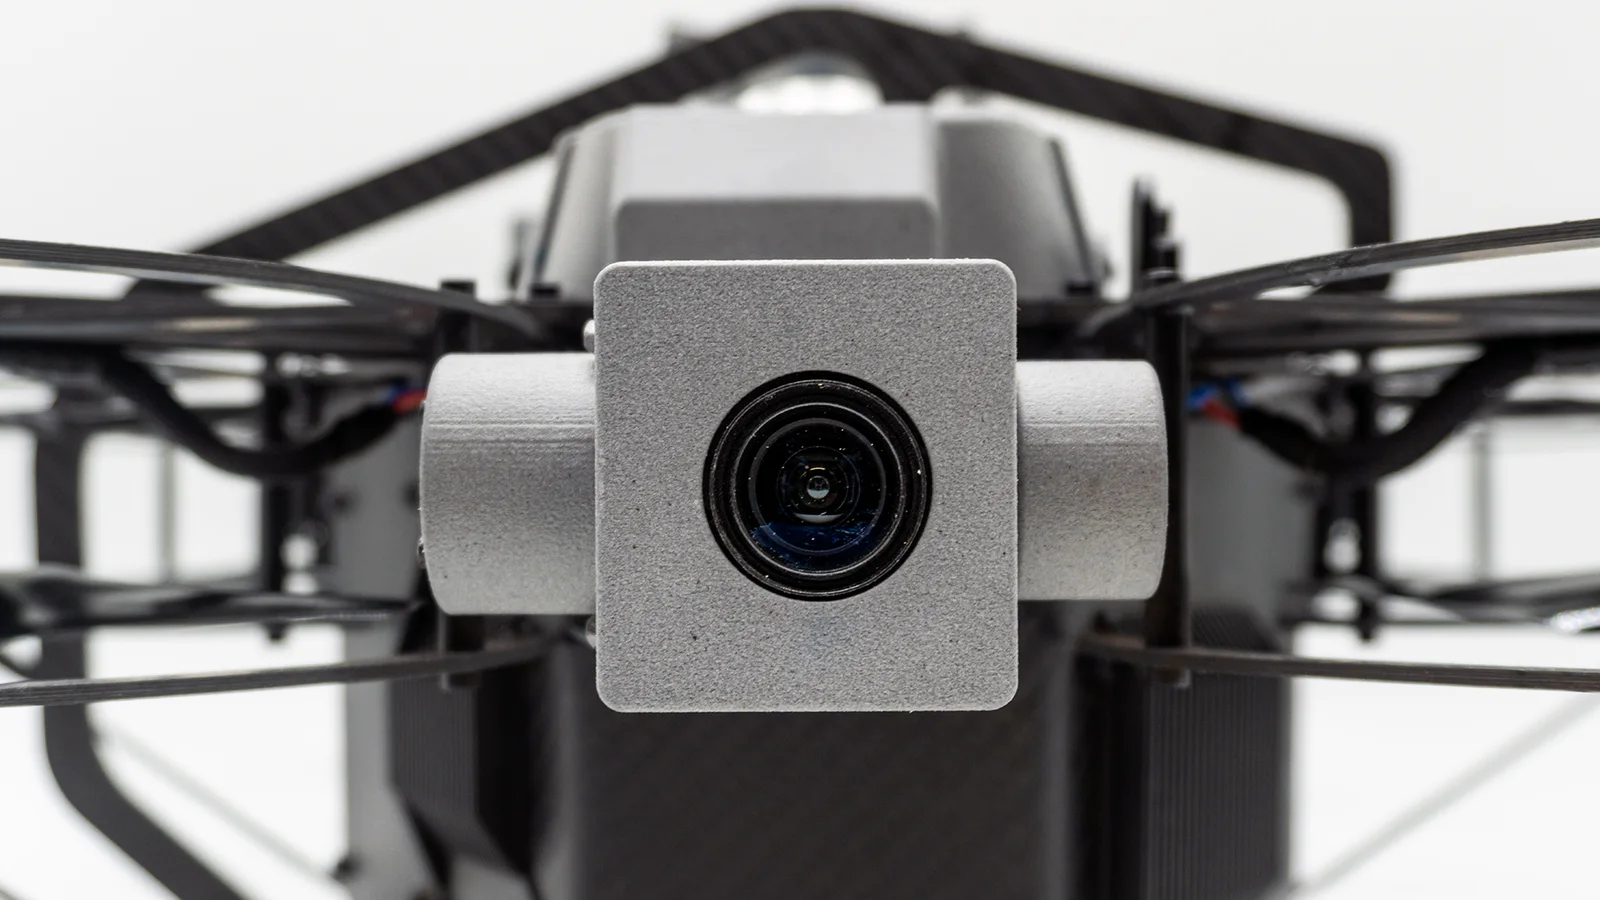
Inside a sealed tank there is no satellite signal and no light. The OS0 doesn’t just measure distance — it captures a camera-grade near-infrared image of every surface, lit by its own laser. So the same sensor that builds the point cloud also sees where it is and flies on it: sub-decimetre positioning in pitch black, with no beacons, no markers and no ground setup.
That coherence is the whole point. Because the drone always knew exactly where it was, every reading from every payload — UT, photo, gas — sits in one consistent coordinate frame, ready to become a single navigable model.
Lands in Scout Portal
After the flight, upload to Scout Portal and the point cloud becomes a navigable 3D model of the asset interior you walk through in the browser, nothing to install. Every UT reading, photo and gas measurement anchors to it in the same coordinate frame.
Inspectors, asset owners and class surveyors review the same model remotely, long after the flight — without anyone re-entering the asset.
What you get out
More than a file. Take measurements anywhere in the 3D model, compare this inspection against the last to see what changed, and generate the report. Engineering and class get an as-built model they can explore for themselves.
And it’s portable: export from Scout Portal to LAZ, PCD, PLY or E57 for Autodesk ReCap, Leica Cyclone, Bentley OpenCities or any digital-twin pipeline. The inspection and the as-built model become the same file.
The LiDAR is already on board. Pilot powers up Scout 137 and loads scan settings tuned to the asset type — no payload to fit, no calibration on site.
Drone flies a systematic pattern through the asset. LiDAR captures the interior surface at up to 5.24 million points per second.
Point cloud builds in real time. Coverage gaps show in Scout Operator, so a re-pass can be flown before the drone leaves the asset.
The point cloud uploads to Scout Portal. Available to inspectors, surveyors and engineering. Exports to PCD and LAZ.

Specifications
Sensor: 128-beam Ouster OS0 Rev 7 (survey-grade)
Range: 0.5 – 75 m (80% reflectivity) 35 m (10% reflectivity)
Field of view: 360° horizontal × 90° vertical
Point rate: Up to 5.24 million points/second (128-channel, dual return)
SLAM: Real-time, same sensor sub-decimetre drone positioning inside the asset
Operates: GPS-free in total darkness no beacons or ground setup
Precision: ±0.8 – 4 cm (1 std-dev, range-dependent) 1 mm range resolution
Exports (via Scout Portal): LAZ high-density PCD, LAZ, PLY, E57 medium-density
CAD & digital-twin compatible: Point-cloud formats import into Autodesk ReCap, Leica Cyclone, Bentley OpenCities, FME and common digital-twin platforms
Integration: Built into Scout 137 Gen 3 always on, not a removable payload
Sensor weight: 430 g
Operating temperature: −20 °C to +50 °C
Laser & ingress: Class 1 eye-safe (865 nm) IP68 / IP69K